This is a warning, not a safety certification. The test uses the TCP of the taught points and the straight lines of linear motions with a tool radius margin. The robot arm, the tool geometry, braking distances, signal dependent activation of the zones and the real cell are not evaluated. The result does not replace the validation of the safety configuration (acceptance protocol). The safety files of the controller are only read.
2026-10-31 16:02
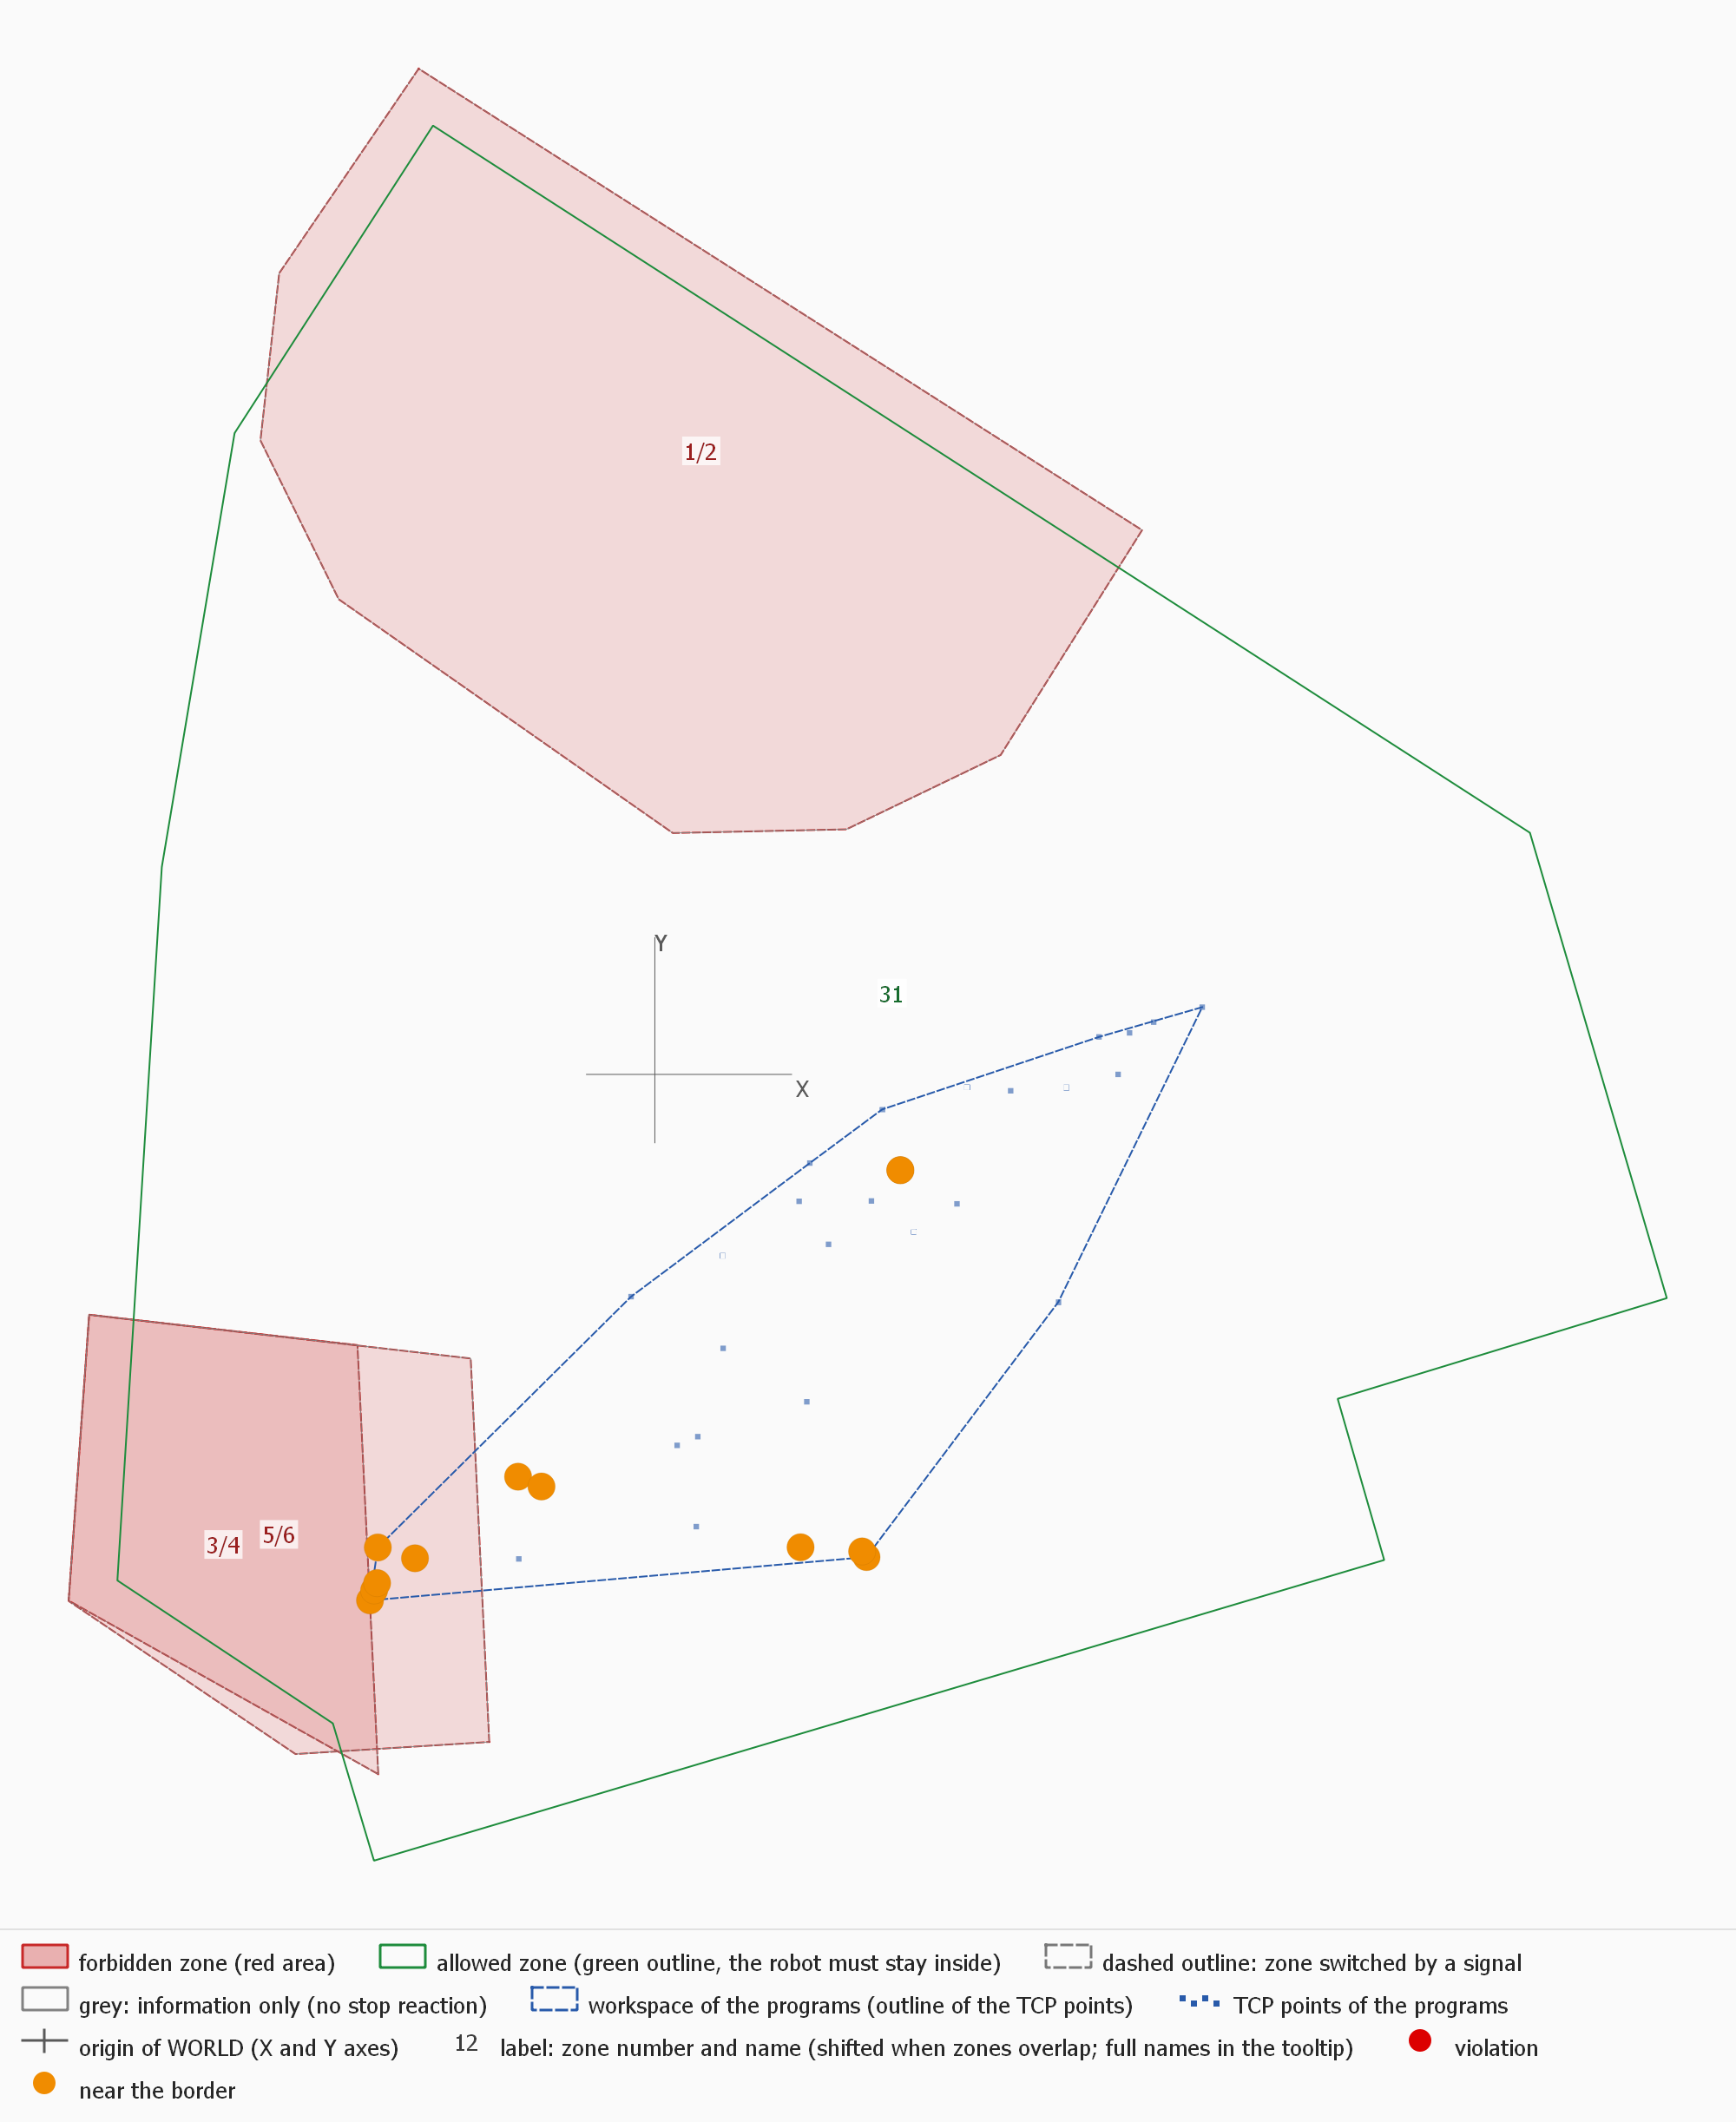
Top view
Side view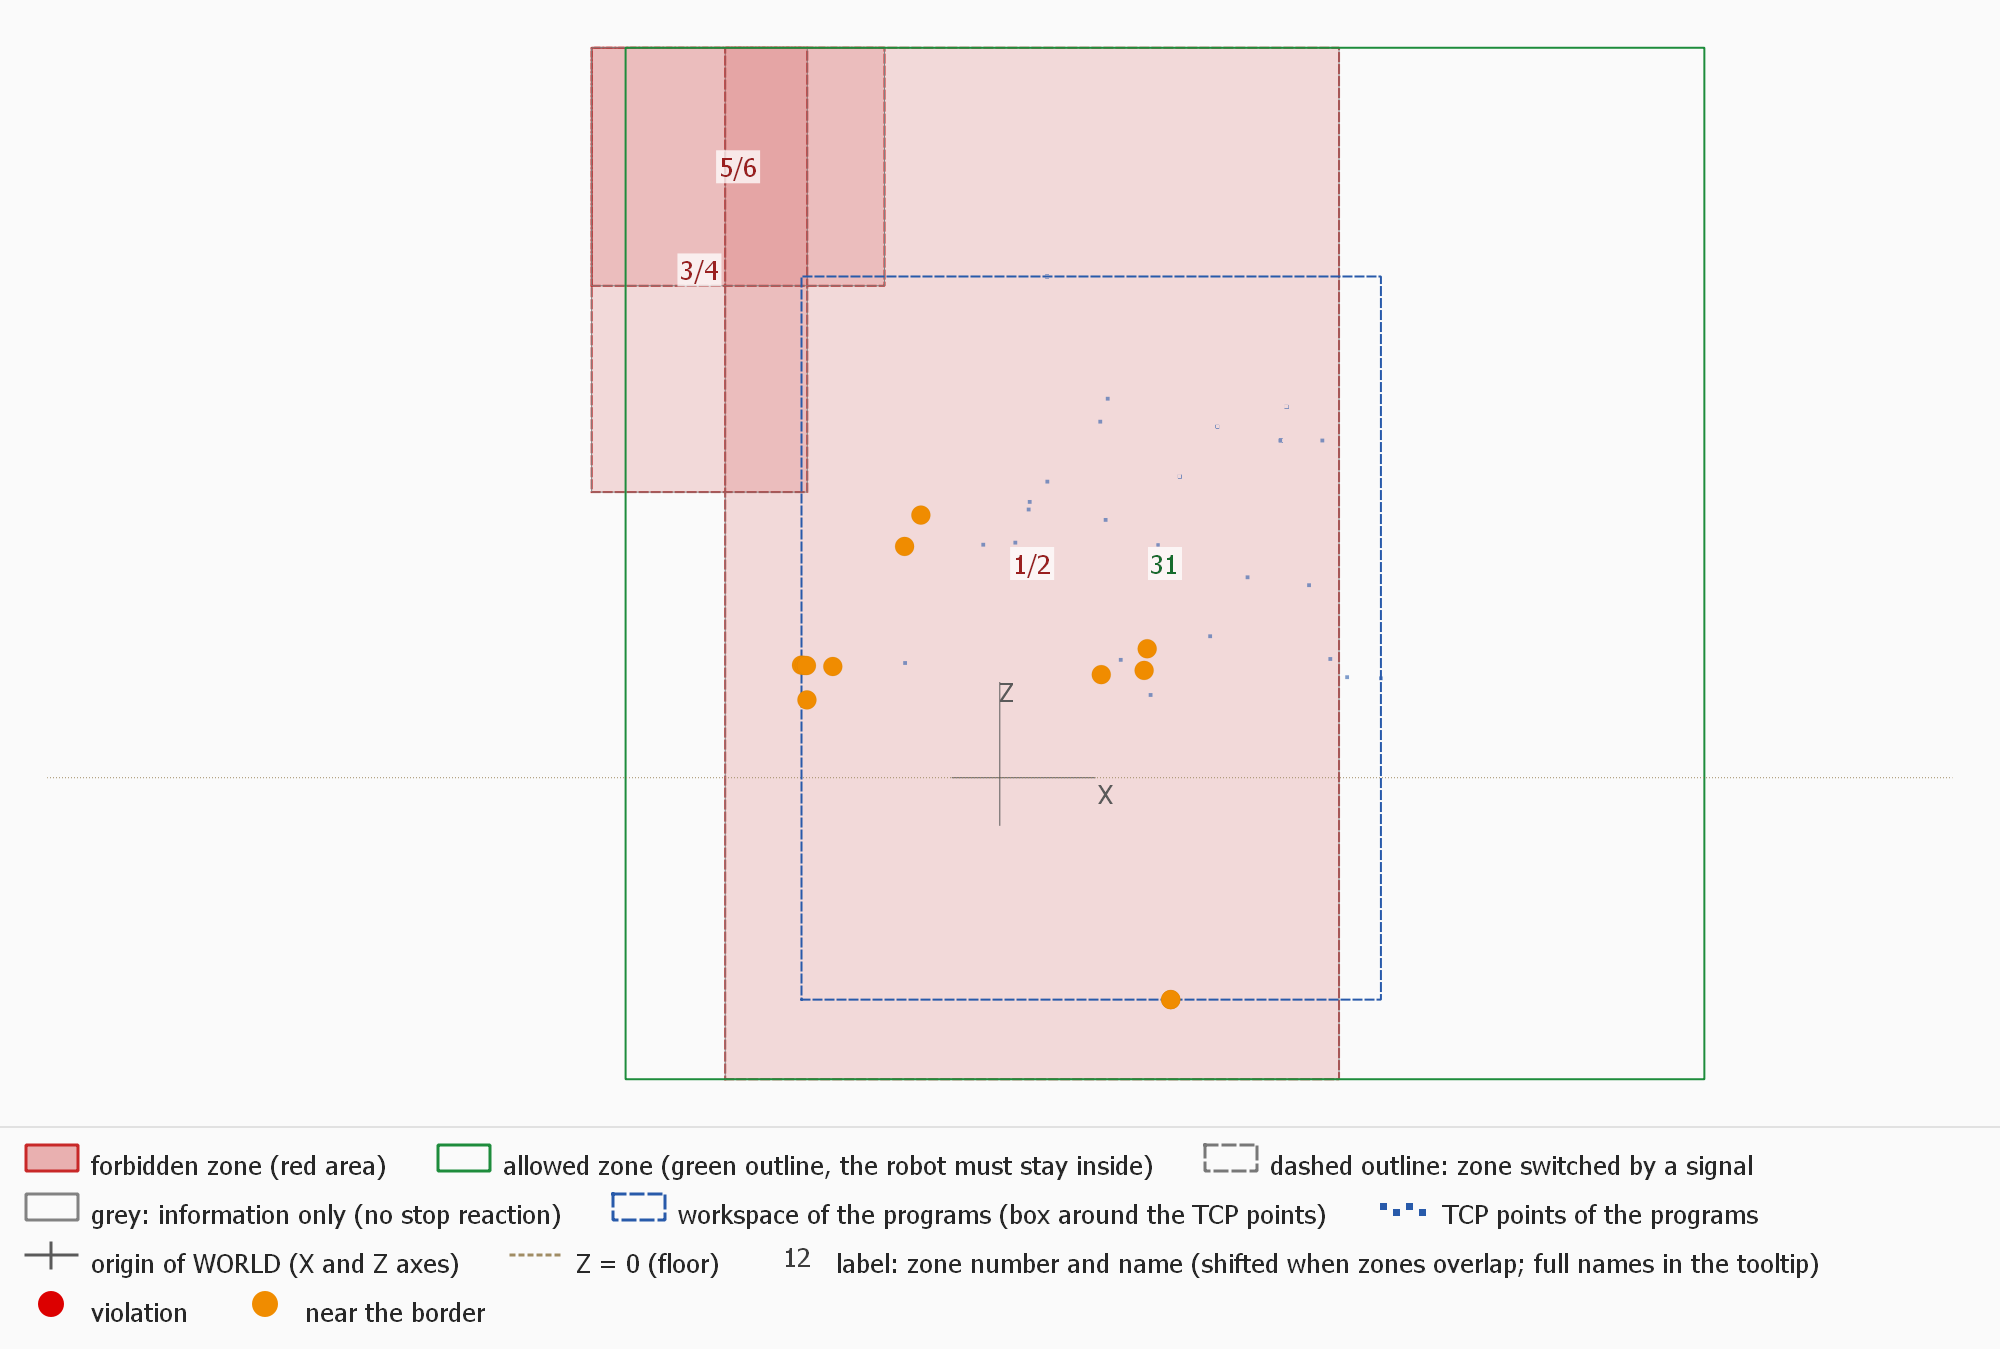
| Item | Value |
|---|---|
| Robot | R1 |
| Controller | ABB |
| Zones | 7 |
| Programs | 3 |
| Motions | 198 |
| Points evaluated | 50 |
| Points not evaluated | 148 |
| Workspace X [mm] | -1250 .. 2402 |
| Workspace Y [mm] | -2308 .. 295 |
| Workspace Z [mm] | -1398 .. 3159 |
| Near border [mm] | 1000 |
| Tool radius [mm] | 0 |
| Violations | 0 |
| Near the border | 12 |
| Note | ABB SafeMove: tool geometry and upper arm capsules are shown in the data only - the test uses the TCP with the tool radius margin |
| Note | ABB: positions are evaluated only for targets in wobj0 (robot base) and moved to WORLD with the Baseframe of the safety configuration |
| Note | point not evaluated: jt_R1_Home1 is not declared in this module or its value is not a literal |
| Note | point not evaluated: jt_R1_Home2 is not declared in this module or its value is not a literal |
| Note | point not evaluated: jt_R1_Home4 is not declared in this module or its value is not a literal |
| Note | point not evaluated: pal_p_LastPart4 is not declared in this module or its value is not a literal |
| Note | point not evaluated: work object pal_wobj_Palette001 (only wobj0 is evaluated) |
| Note | point not evaluated: work object pal_wobj_Palette002 (only wobj0 is evaluated) |
| Note | point not evaluated: work object pal_wobj_Palette003 (only wobj0 is evaluated) |
| Note | point not evaluated: work object pal_wobj_Palette004 (only wobj0 is evaluated) |
| Note | point not evaluated: work object wobj_020FX001 (only wobj0 is evaluated) |
| Note | point not evaluated: work object wobj_020TD001 (only wobj0 is evaluated) |
| Note | point not evaluated: work object wobj_020td001 (only wobj0 is evaluated) |
| Note | point not evaluated: work object wobj_Grp_FZ0_G20 (only wobj0 is evaluated) |
| Warning | This is a warning, not a safety certification. The test uses the TCP of the taught points and the straight lines of linear motions with a tool radius margin. The robot arm, the tool geometry, braking distances, signal dependent activation of the zones and the real cell are not evaluated. The result does not replace the validation of the safety configuration (acceptance protocol). The safety files of the controller are only read. |
| No. | Name | Type | Shape | Z min [mm] | Z max [mm] | Frame | Activation | Stop | Models | Min margin [mm] | Violations | Near | Status |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| 1 | Zone 1 | forbidden | polygon | -1900 | 4600 | WORLD | input fdi_Rel_Zone_01 | Category1Stop | tool + robot (includeRobot) | 1239 | 0 | 0 | evaluated |
| 2 | Zone 2 | forbidden | polygon | -1900 | 4600 | WORLD | Permanent | NoStop | tool + robot (includeRobot) | information only | |||
| 3 | Zone 3 | forbidden | polygon | 1800 | 4600 | WORLD | input fdi_Rel_Zone_02 | Category1Stop | tool + robot (includeRobot) | 758 | 0 | 2 | evaluated |
| 4 | Zone 4 | forbidden | polygon | 1800 | 4600 | WORLD | Permanent | NoStop | tool + robot (includeRobot) | information only | |||
| 5 | Zone 5 | forbidden | polygon | 3100 | 4600 | WORLD | input fdi_Rel_Zone_03 | Category1Stop | tool + robot (includeRobot) | 1194 | 0 | 0 | evaluated |
| 6 | Zone 6 | forbidden | polygon | 3100 | 4600 | WORLD | Permanent | NoStop | tool + robot (includeRobot) | information only | |||
| 31 | Zone 31 | allowed | polygon | -1900 | 4600 | WORLD | Permanent | Category1Stop | tool + robot (includeRobot) | 502 | 0 | 10 | evaluated |
| Level | Zone | Zone name | Kind | Margin [mm] | Program | Point | Line | X [mm] | Y [mm] | Z [mm] | Zone switched by signal |
|---|---|---|---|---|---|---|---|---|---|---|---|
| near | 31 | Zone 31 | point | 502 | R1_program.mod | [literal, line 296] | 296 | 1077 | -420 | -1398 | no |
| near | 31 | Zone 31 | point | 502 | R1_program.mod | [literal, line 367] | 367 | 1077 | -420 | -1398 | no |
| near | 31 | Zone 31 | point | 540 | R1_program.mod | laser_pos | 970 | -1250 | -2308 | 710 | no |
| near | 31 | Zone 31 | point | 586 | R1_program.mod | [literal, line 968] | 968 | -1232 | -2264 | 708 | no |
| near | 31 | Zone 31 | point | 620 | R1_program.mod | [literal, line 975] | 975 | -1219 | -2232 | 707 | no |
| near | 31 | Zone 31 | point | 660 | R1_program.mod | [literal, line 682] | 682 | 929 | -2118 | 813 | no |
| near | 31 | Zone 31 | point | 690 | R1_program.mod | [literal, line 690] | 690 | 909 | -2093 | 676 | no |
| near | 31 | Zone 31 | point | 752 | R1_program.mod | laser_check | 977 | -1215 | -2076 | 490 | no |
| near | 3 | Zone 3 | point | 758 | R1_program.mod | [literal, line 985] | 985 | -600 | -1765 | 1458 | yes |
| near | 31 | Zone 31 | point | 784 | R1_program.mod | Sichtposition | 684 | 639 | -2075 | 650 | no |
| near | 3 | Zone 3 | point | 790 | R1_program.mod | [literal, line 983] | 983 | -497 | -1808 | 1655 | yes |
| near | 31 | Zone 31 | point | 803 | R1_program.mod | [literal, line 967] | 967 | -1052 | -2123 | 701 | no |