By clicking the right mouse button on the opened
VKRC program the user gets fast access to many useful options and shortcuts.
Below we describe some of the most helpful shortcuts.

|
»
|
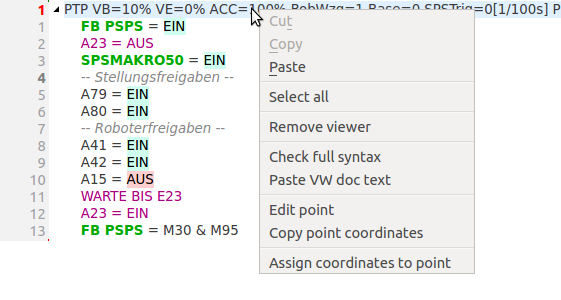
Via the motion point's context menu the user can access some useful point actions.
|
- Cut - currently selected text (simple text, points, comments, subfolds). The key shortcut is Ctrl + X.
- Copy - currently selected text. The key shortcut is Ctrl + C.
- Paste - paste the text from the clipboard. You can copy and paste the text between two files in one session and
from one opened DReS instance to another one. The key shortcut is Ctrl + V.
- Select all - select the entire text in the editor.
- Remove viewer - remove the VKRC viewer for the current file and display the source text for the src file.
- Check full syntax - check if the current program syntax is correct, e.g.: if the variable name and range do not exceed
the allowed range, command's order, jumps and labels etc...
- Paste VW doc text - paste the text that was copied from VW Standard Documentation.
All line numbers from the text in the clipboard in the format 1: at the beginning of each text line and
all comments, e.g.: ~ Schutzgitter gesperrt at the end of the text line will be removed automatically.
- Edit point - open the point editor widget for the text line under the mouse cursor.
Go to reference documentation for more details.
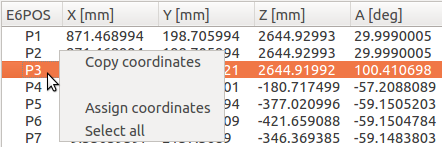
- Copy point coordiantes - copy point's coordinates to the clipboard. You can copy and assign
point's coordinates between different files and DReS instances.
- Assign coordiantes to point - assign point's coordinates to the point under the mouse cursor.
|
|
|
»
|
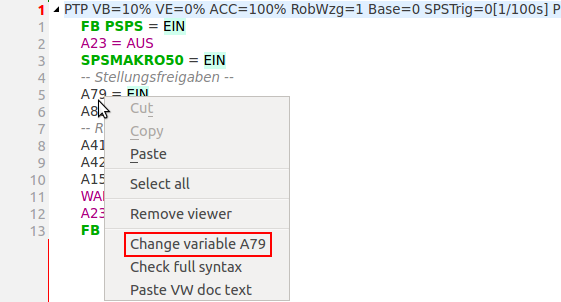
If you pop up the context menu for a variable you will have access to the following options.
|
Change variable - changes the variable in the current file, in all opened files or in all
Folgen, UPs and Makros of the robot, see Change variable.
|

|
»
|
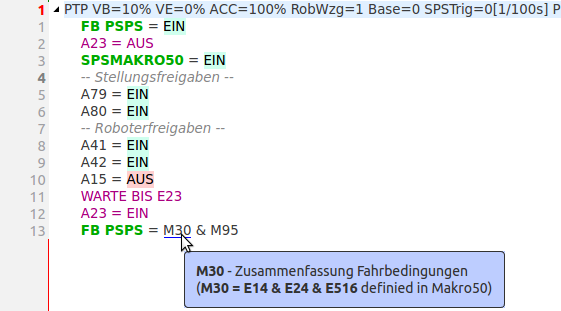
If you press the Ctrl button and move the mouse cursor over merker you can go to the place where this variable is defined.
Just press the left mouse button now. If you do the same for the makro call you can jump into that makro.
|
|
|
»
|
|
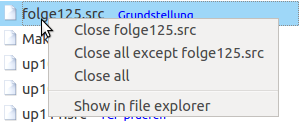
If you pop up the context menu for an item in a file tree you can close the file or close everything, except for the one that you want
to leave open.
You can also open the system file explorer with the location where this file exists.
|
|
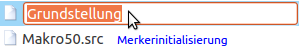
If you double click the file item on the file tree you can change a file comment.
This change will take effect if you save the file.
|
|
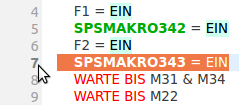
If you press the line number on the left margin you can easily select the whole text line.
|
|
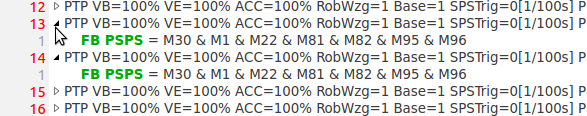
By clicking on the black or white triangle you can open or close the chosen fold.
If you do the same with pressed Ctrl button you will open or close all folds in the current program.
We also defined a shortcut to fire this action - Ctrl + Q.
|
|
For the selected point in the point tree table you can easily copy and assign the point's coordinates.
|
Open documents – sorting and robot name
The context menu of the list Open documents works for the files of all controllers (VKRC, KRC, Fanuc, ABB, Yaskawa):
- Sort by > Name, Last Modified, Absolute Path or Robot name – with Robot name
the files are grouped by the robot project they belong to (in the project tree); within a robot they are sorted as by name,
files without a robot project are at the end. The chosen sorting is kept after a restart of DReS.
- Show robot name as prefix – checked: the robot name is shown in gray before every file name, e.g. 0001R01 - folge81.
Not checked: the robot name is shown only before files with the same name that are open from several robots.
- Robot name > Full name (e.g. ABC1D1235670R01) or Short name VASS (e.g. 5670R01) – the short VASS name
consists of the last 4 digits before R, the letter R and the robot number with 2 digits
(ABC1D1235670R01 → 5670R01). Names without this pattern are shown in full.
The settings are kept after a restart. Scripts and the AI agent set them with the command documents_view
(see Editor API).
Export langtext for all robot projects
Tools > Export langtext for all robot projects to separate files... (also in the context menu of a robot in the project tree,
right after Load extra long texts) saves the long texts (signal descriptions) of every robot project of the project tree to
separate files, one per robot, in a chosen folder. The texts are read from the robot data on the disk, no program has to be open.
In the dialog you choose the format:
- CSV for all robots (E41;text) – file <robot>_longtext.csv with one line
E41;text per signal, for all controllers.
- Native format of the controller:
- VKRC – text file like the RefListe.txt (
E41 text), file <robot>_RefListe.txt,
- KRC – text file (
IN[1] text), file <robot>_longtext.txt; WorkVisual projects cannot be written,
- Fanuc – DT file (
IO_COMMENT_DI-1 : text), file <robot>_IO_COMMENT.dt,
- ABB – a copy of the EIO.cfg of the robot (texts in -Label), file <robot>_EIO.cfg,
- Yaskawa – a copy of the IONAME.DAT of the robot, file <robot>_IONAME.DAT.
The texts of VKRC come from the WorkVisual project of the archive or else from the reference list set in the settings, of KRC only from
the WorkVisual project. At the end a summary shows the saved files with the number of texts and the robots that were not saved with
the reason (e.g. no long text file, missing license of the editor). Scripts and the AI agent use the command export_longtexts
(see Editor API).
Collision map of the robot projects
Tools > Collision map of the robot projects... builds the interlock (collision) map robot–robot of all or of the chosen
open robot projects. Only KUKA VKRC and Fanuc in the VW standard are supported, mixed stations are allowed; other controllers are skipped.
The map uses the same interlock analysis as the Robot Cell Simulator and the Robot Collisions Analyzer: it is a signal analysis of the
program code (requests, zones, releases), not a geometric collision check, and the programs are never changed. The partners and the
descriptions of the zones come for VKRC from the long texts (WorkVisual project or reference list and the long texts of the controller),
for Fanuc from the reference list (DI-41 / DO-81); zones still without a description get the comments of the programs.
In the dialog you set:
- robot projects – list with check boxes (projects of other controllers are disabled),
- Programs – base names, e.g. folge81, up42; empty = every Folge with its UPs,
- Title of the report and File – path without extension (button ... to browse),
- Formats – SVG, PNG, HTML, PDF, CSV, XLSX, JSON (default PNG and HTML).
The outputs:
- SVG / PNG – graph with a card per robot (requests, zones, programs, number of errors and warnings), lines between the
partners with circles of the zone numbers: green = zone used by both robots, red dashed = used by one side only; panel of the
findings, legend and footer,
- HTML / PDF – report with the graph, the matrix, the partner check and the remarks of the signal logic,
- CSV – sections ROBOT, CELL, SLOT, FINDING; XLSX – sheets Matrix, Pairs, Partners, Remarks; JSON.
At the end a message shows the numbers of robots, pairs and findings and the written files, and offers to open the first file.
Licenses: API / CLI (248) and AI agent knowledge (247). Scripts and the AI agent use the command collision_map
(see Editor API).
