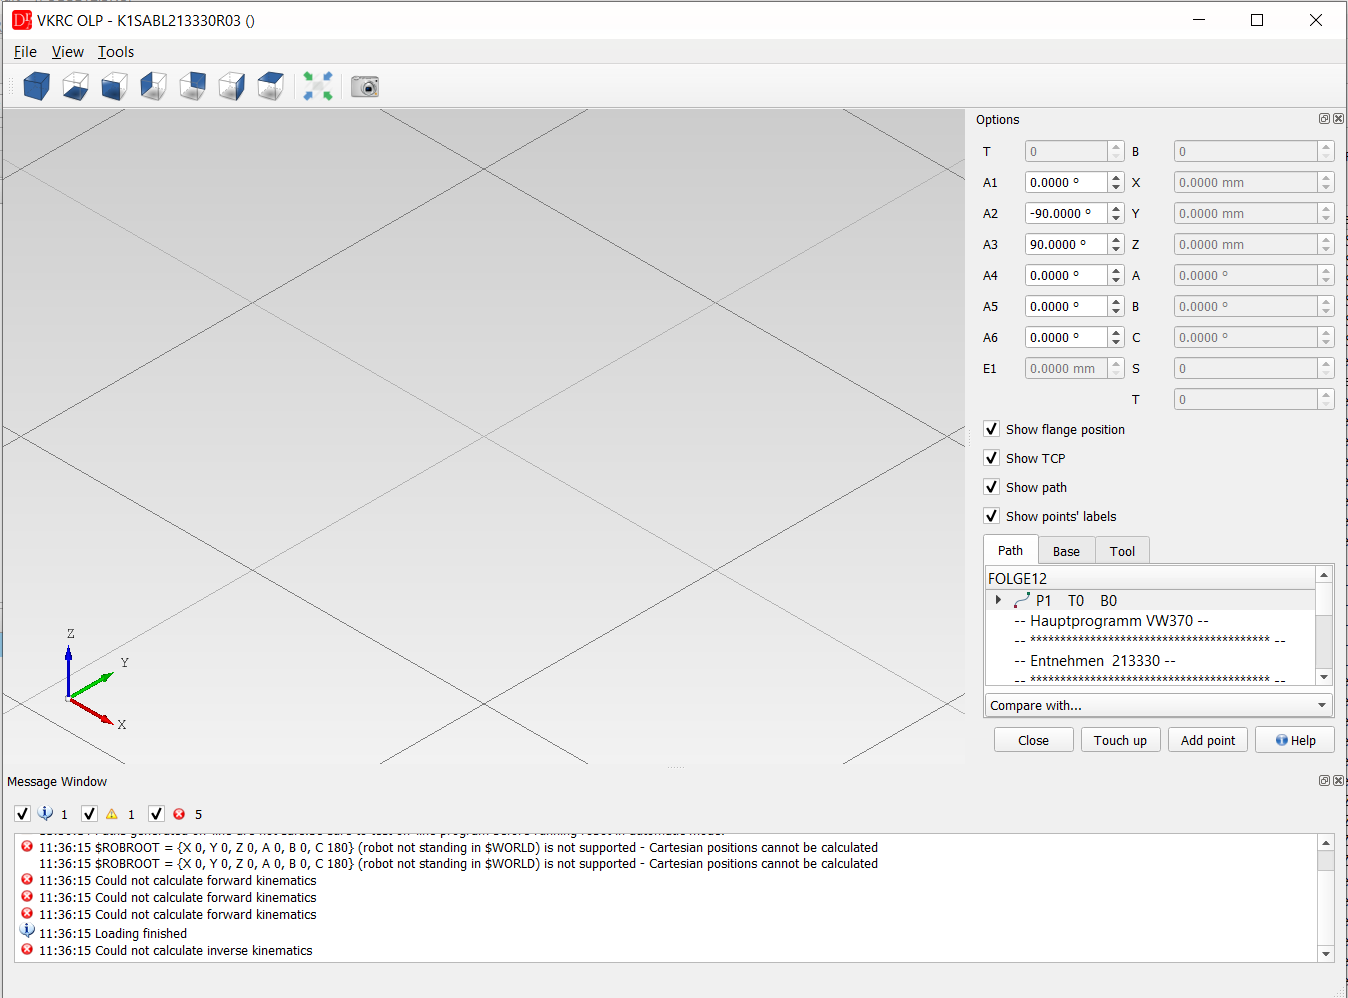
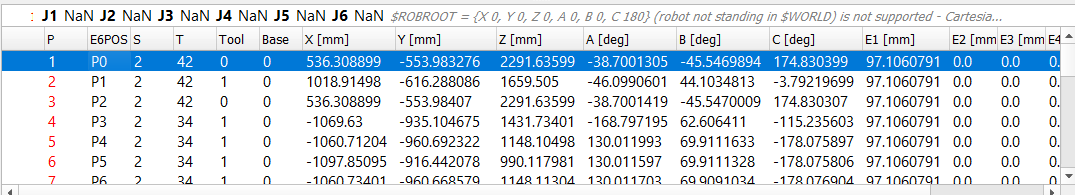
The KRC OLP plugin (menu KRC » Plugins » KRC OLP) shows the program opened in the KRC viewer in a 3D environment: the robot (CAD model from the CAD repository or a dummy model built from the kinematics of the robot), all motion points of the program as a path, the base frames and the TCP.
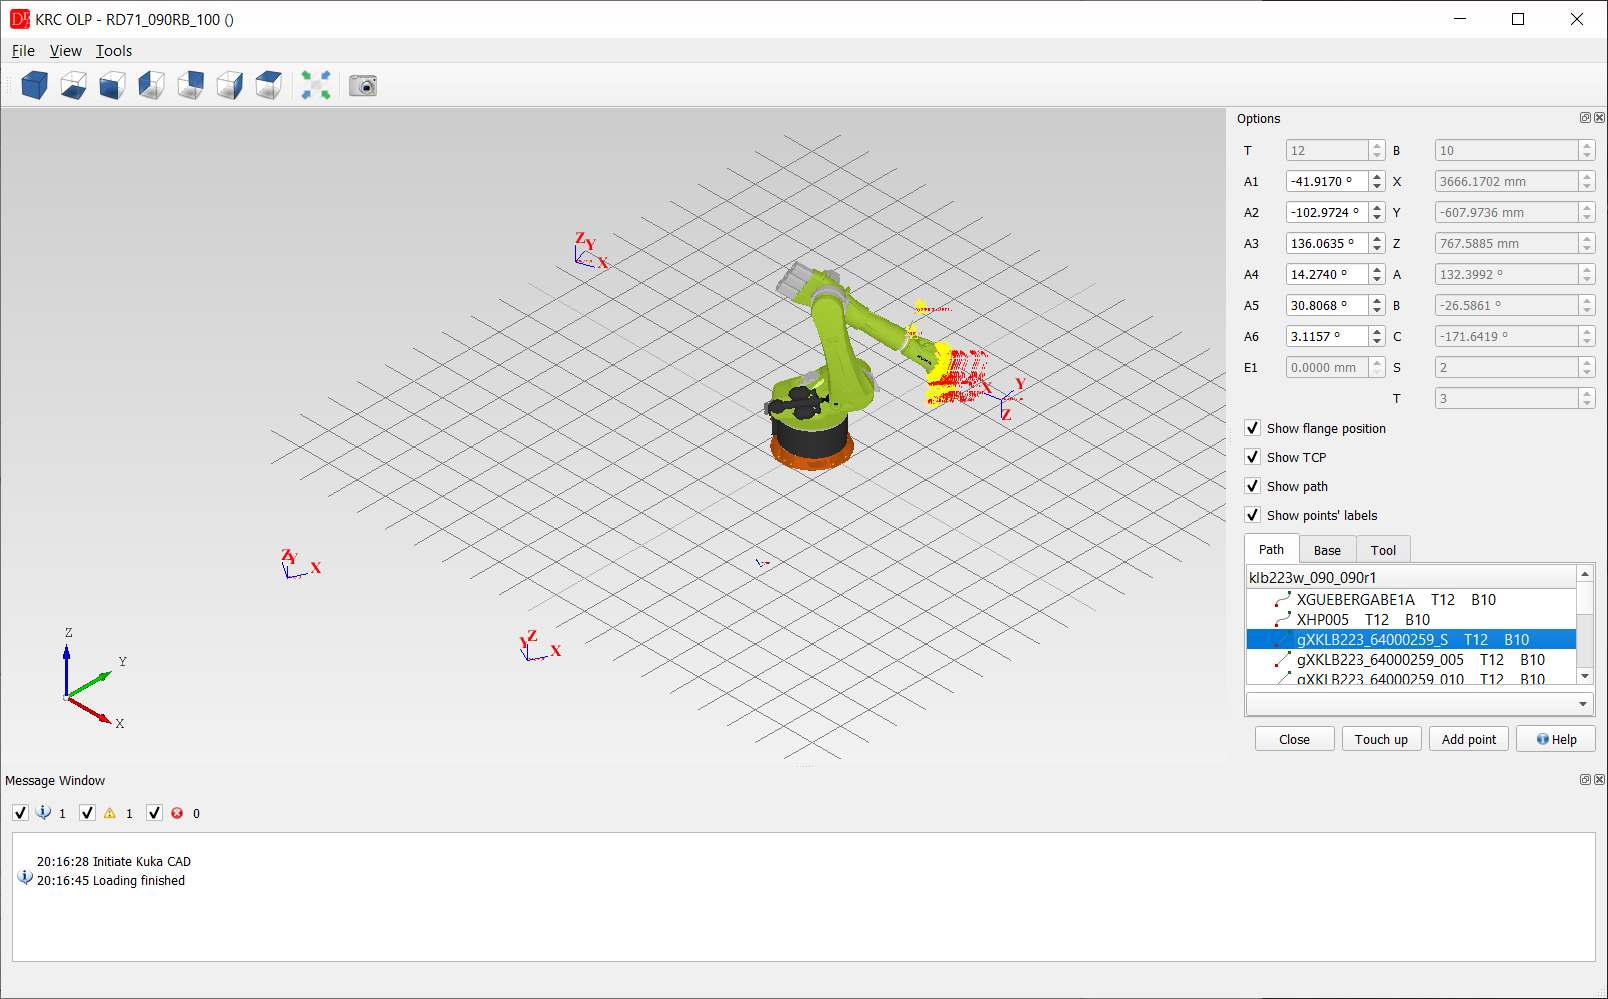
Window
- 3D view - robot model, path of the program, frames and TCP; views (axonometric, front, top ...), Fit in view and Grab the preview (export of the view to an image) in the toolbar,
- View menu - display mode (shaded / wire frame), grid on / off,
- Tools menu - add a cube or a sphere to the scene (e.g. to check a fence or an obstacle), grab the preview, Options (grid and colour settings),
- Message Window - information about the model, the kinematics and the points (errors, axis limits, unreachable positions).
- T / B - tool and base of the selected point,
- A1 .. A6, E1 - axis values; changing them moves the robot, the Cartesian position X, Y, Z, A, B, C and the configuration S / T are calculated (forward kinematics),
- Show flange position - Cartesian values of the flange instead of the TCP,
- Show TCP, Show path, Show points' labels, Show range (work envelope),
- Path - all motions of the program (PTP / LIN / CIRC); selecting a point moves the robot to it,
- Base - base frames of the robot, each can be shown or hidden,
- Tool - CAD models of tools (STEP) which can be mounted on the flange,
- Compare with... - draws the path of another program of the same robot.
- Touch up - writes the current position of the robot to the selected point,
- Add point - adds a new motion with the current position after the selected point.
Touch up and Add point change the program in the editor (the file is saved as usual) and require the
KRC license. Paths generated off-line are not safe - test an off-line program before running the robot in
automatic mode.
Robot mounting: only a robot standing in $WORLD ($ROBROOT = {0,0,0,0,0,0} in
$machine.dat) or a robot on the E1 linear unit ($ERSYSROOT = 0) is supported. For another $ROBROOT
(ceiling, wall, shifted robot) no Cartesian positions are calculated and the robot is not drawn - the message
window shows the $ROBROOT value.